Physical test record
Record accepted placements, damage, cycle time and operator interventions across the agreed sample set.
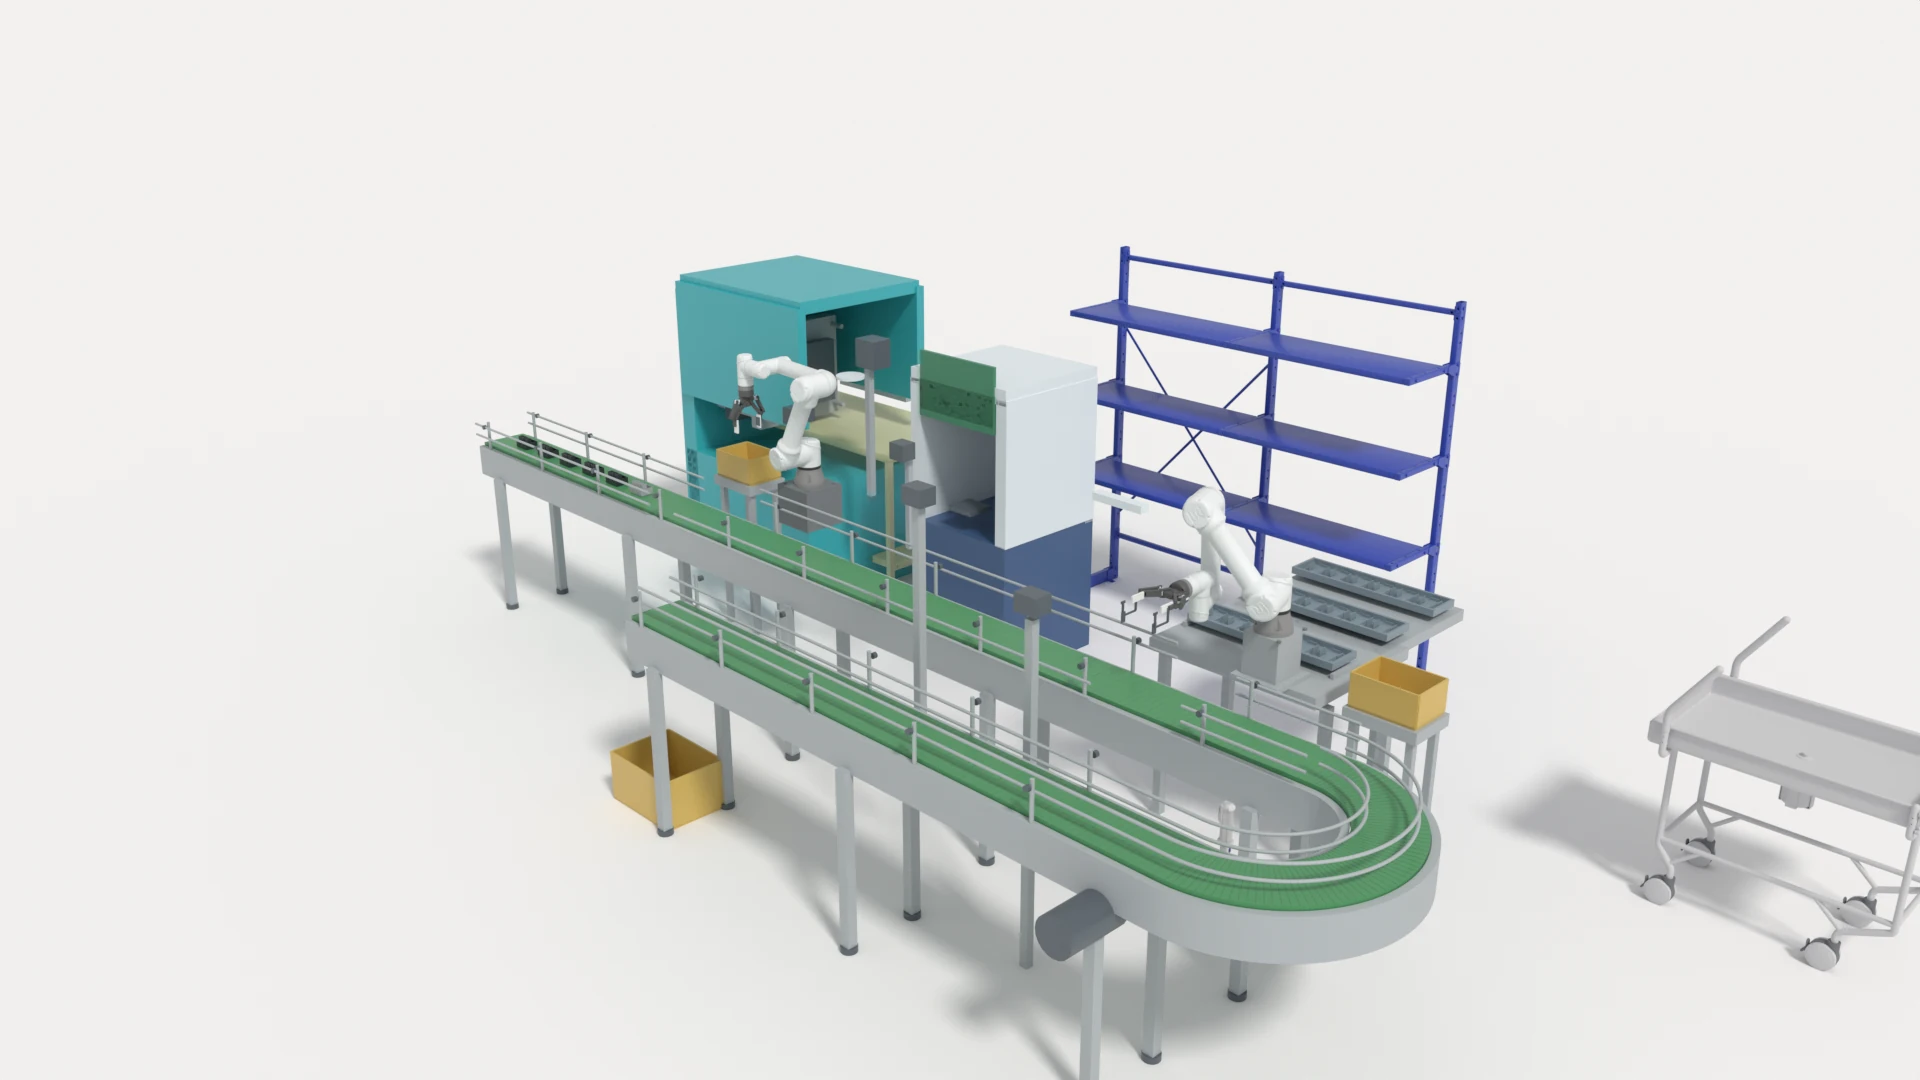
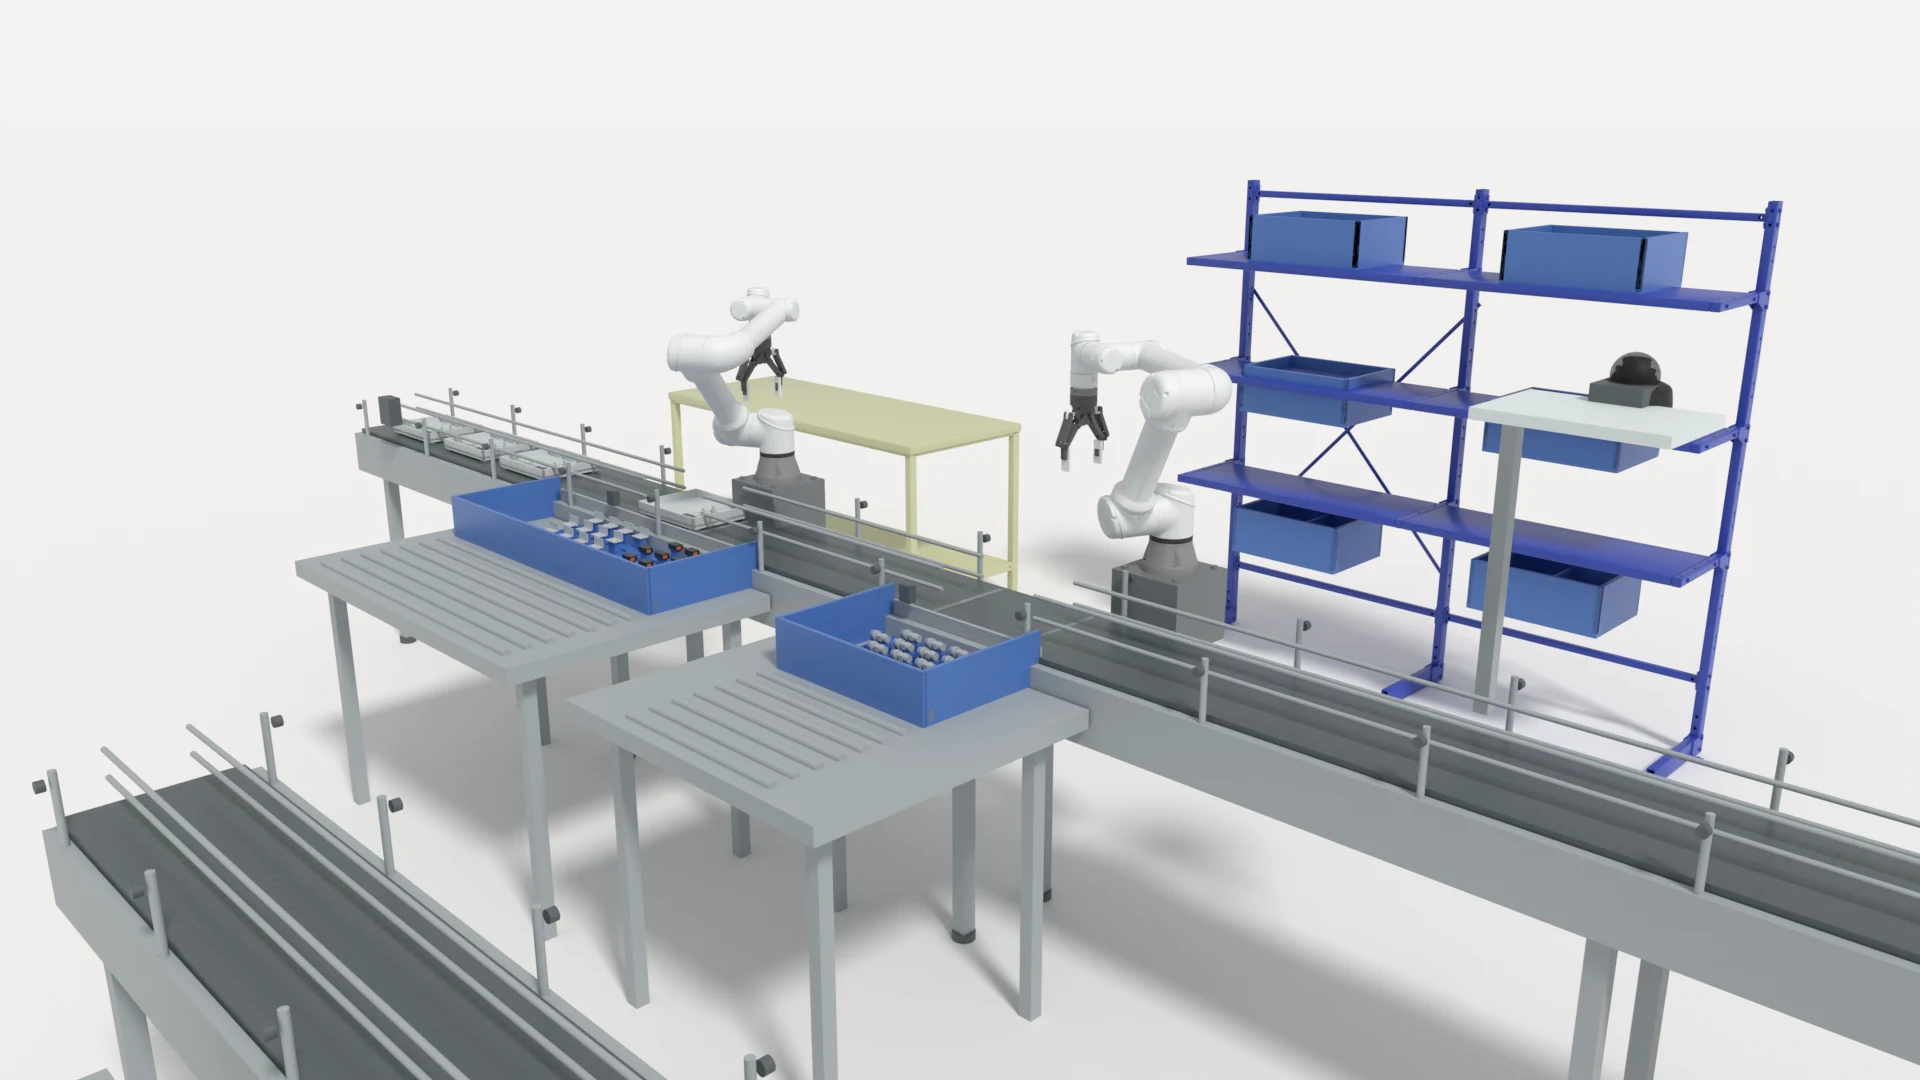
Check robot reach and station handoffs before building. Test the proposed cycle with real parts.
We simulate robot motion and equipment handoffs before building the station. Bench trials with your parts then verify grip, placement and cycle time.
Use the layout to identify what to test at the bench, then verify the agreed acceptance criteria with production parts.
Record accepted placements, damage, cycle time and operator interventions across the agreed sample set.
Test what happens when the receiving station is occupied, a pick fails or the cycle restarts with a part already in the gripper.