Part families and changeovers
Use your part family, fixture options and batch sizes. Time a normal changeover with the fixtures and replenishment you use.
Automate machine loading, part inspection and packout on your existing production line.
We build robotic stations for machine loading, inspection and packout on existing production lines.
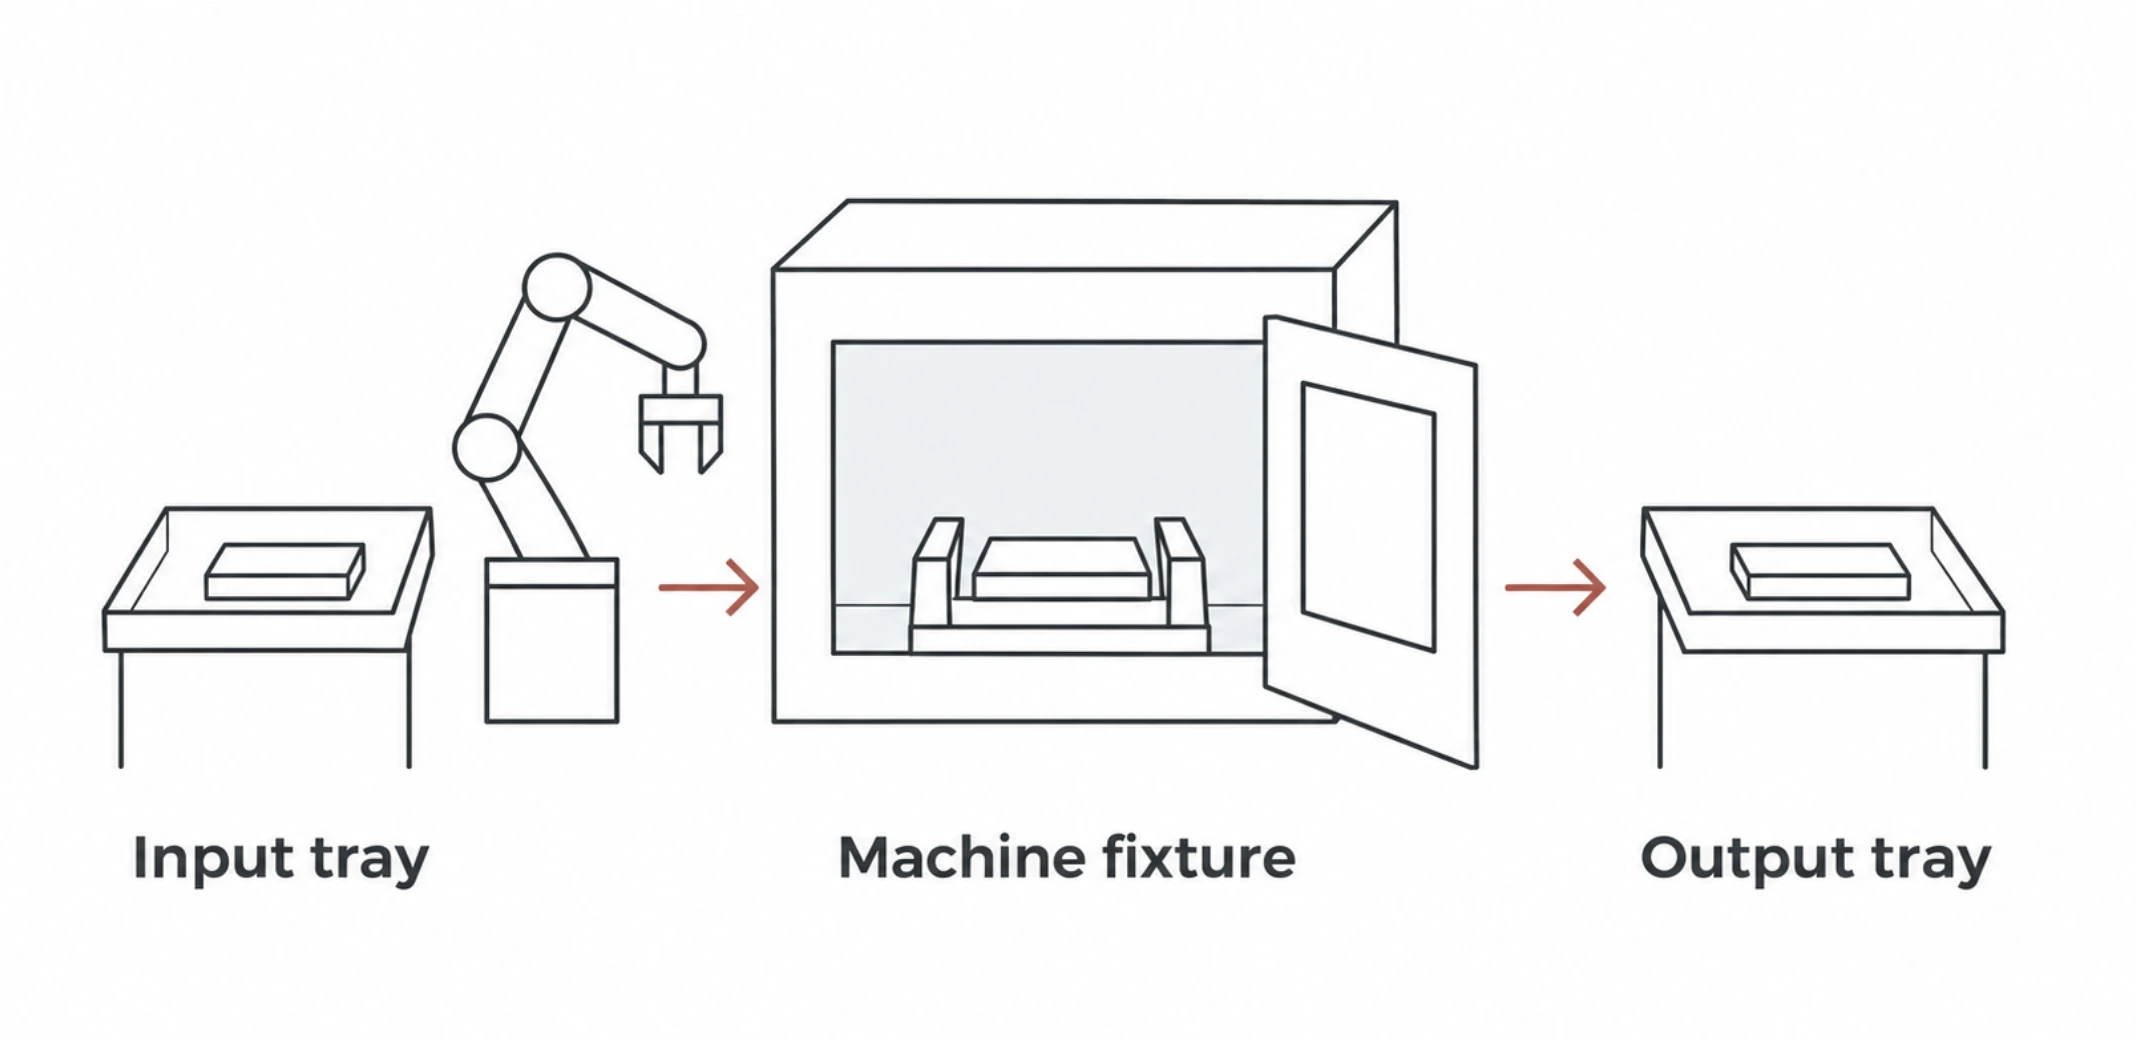
Use your part family, fixture options and batch sizes. Time a normal changeover with the fixtures and replenishment you use.
Agree what signals a part is ready, when the next machine can accept it and where parts go if the line backs up.
A robot takes molded parts from the machine to camera inspection and code verification. The existing conveyor carries accepted parts to packout.
We review guarding at transfer points and operator access with your team. For U.S. projects, that review can include ANSI/A3 R15.06-2025 for industrial robot systems and OSHA 29 CFR 1910.212 for machine guarding.