SF Robotics
Discuss a project

Picking & handling

Robot picking, sorting and transfers for warehouse and production lines.

What we develop

We build robotic picking and transfer stations for warehouses, production lines and fabrication shops.
  • Pick from existing equipmentRetrieve items from bins, racks or conveyors using camera guidance, vacuum tooling or jaw grippers suited to the part.
  • Sort by order or destinationUse the order assignment or line signal to route items into the right tote, lane or station.
  • Set the orientationTurn the part to match the receiving fixture or pack station. Check the placement before releasing the part.
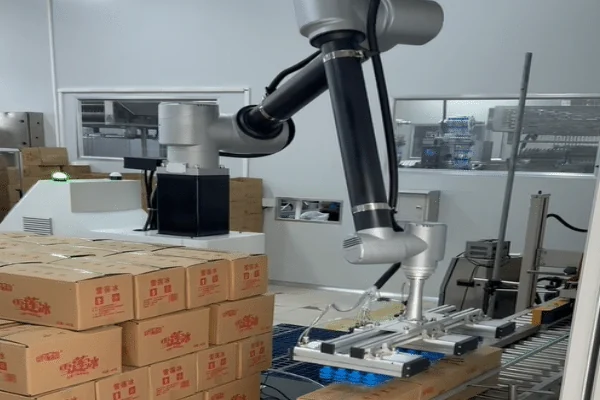
Robot with a vacuum gripper transferring a carton beside a conveyor
Robotic carton handling

From pickup to the next station

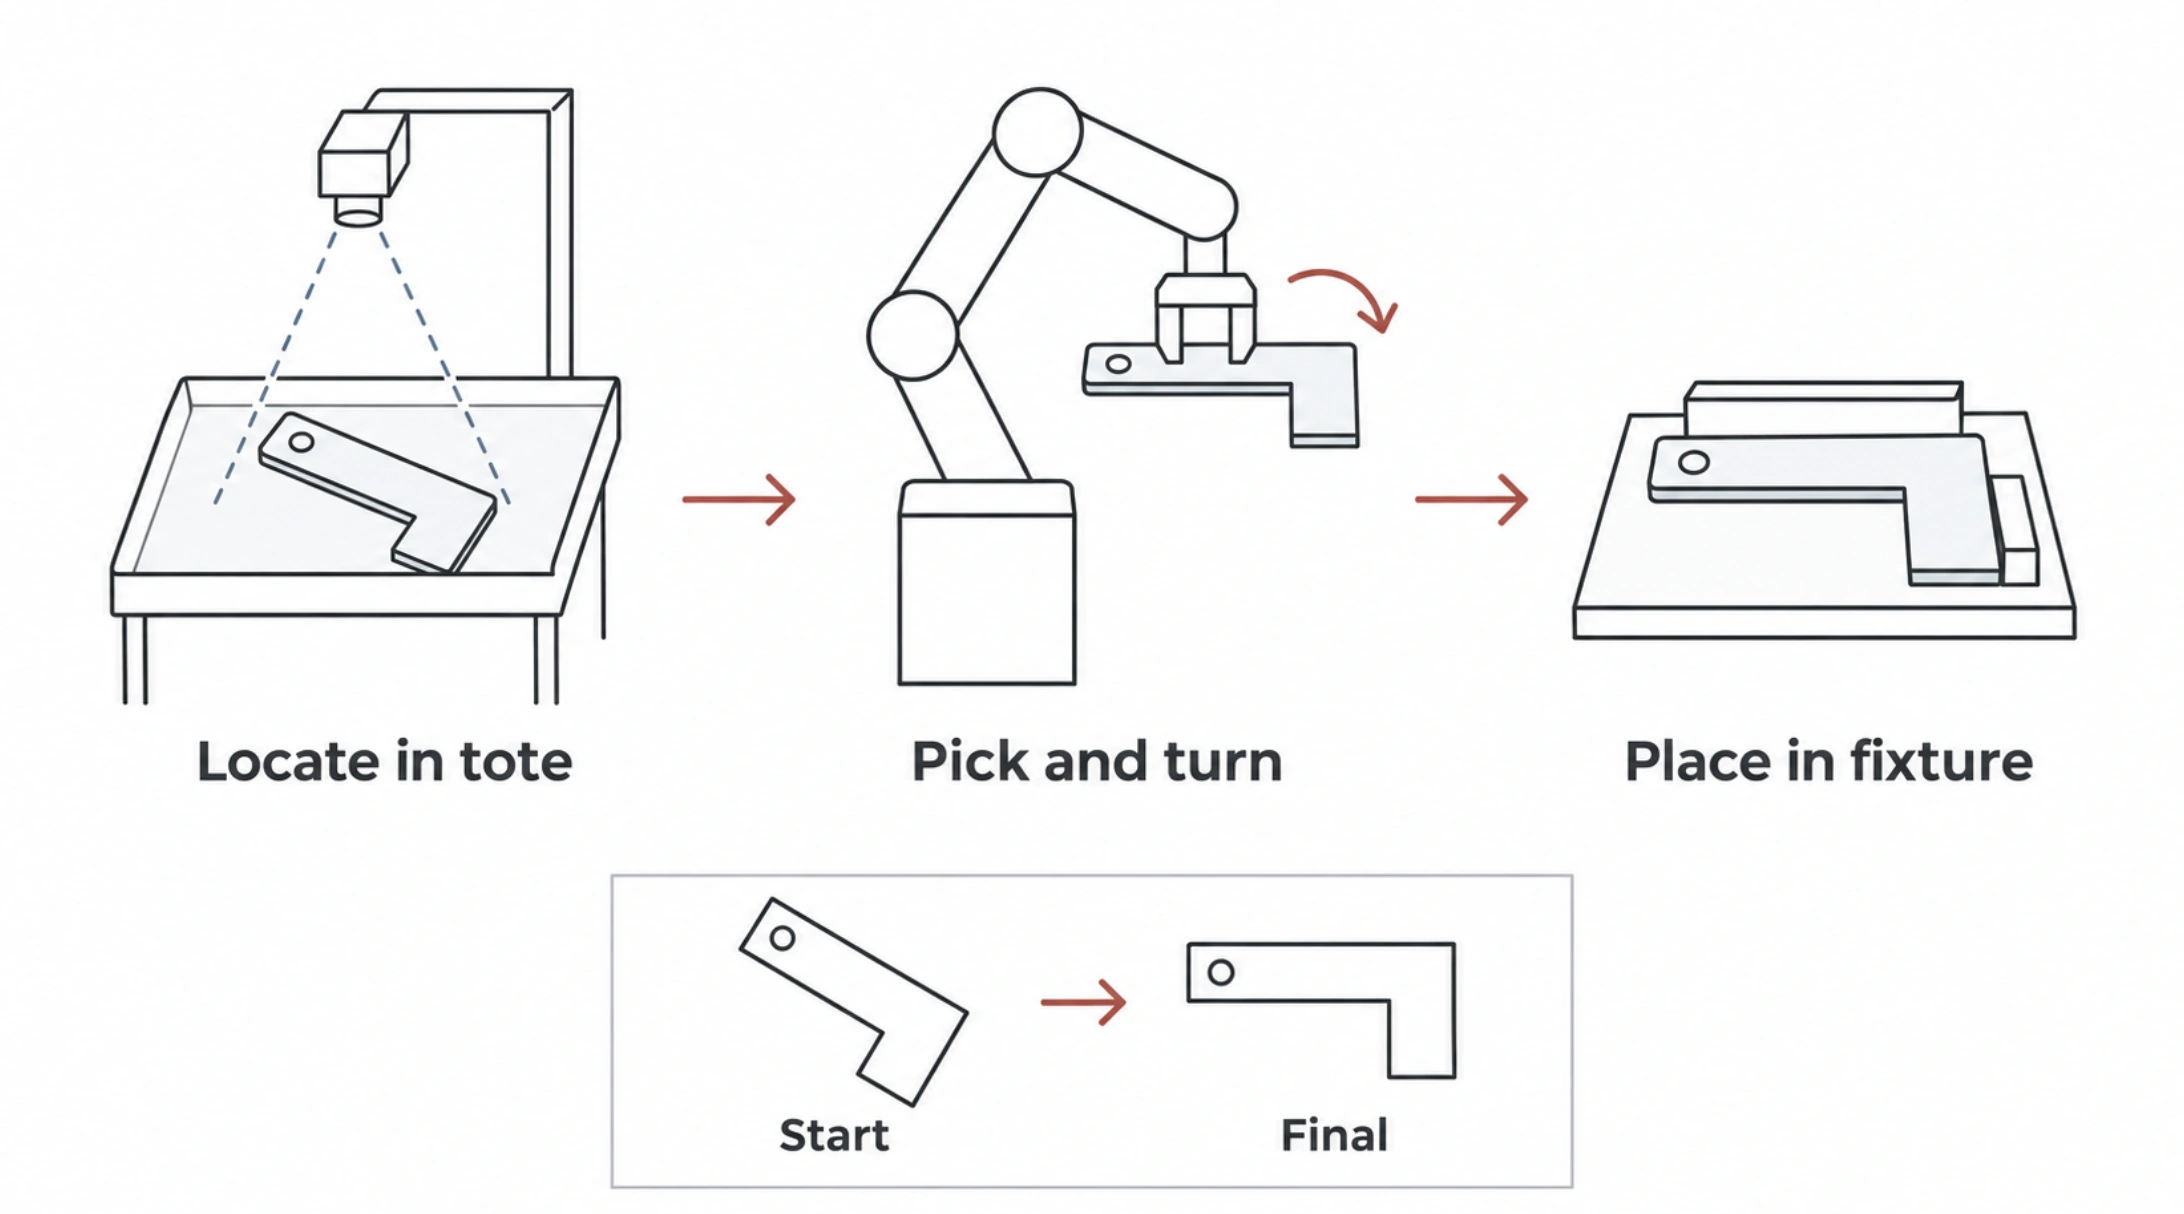
  1. Locate the item on an existing conveyor, rack or tote.
  2. Grip it at an allowed contact surface and turn it to the requested orientation.
  3. Confirm placement in the order tote, conveyor lane or receiving fixture.
A camera locates a rotated part in a tote. A robot picks and turns it, then places it in a fixture.

Gripper contact

Check weight, surface finish and where jaws or suction can touch. Include fragile, slippery or flexible pieces in the trial.

Placement tolerance

Bring the source bins and receiving fixtures. Test separated and mixed items, the required orientation and how much placement error the next station accepts.

First-pass picks

Measure confirmed placements, damage and operator assists with the actual item mix.

Discuss an automation project

Contact SF Robotics