GR00T N1.6
SF Robotics co-founder Rahul Chand contributed to NVIDIA’s GR00T N1.6 foundation model for humanoid robots.
Read our prior research at NVIDIAAdapt robot behavior to new parts, positions and tasks using demonstrations.
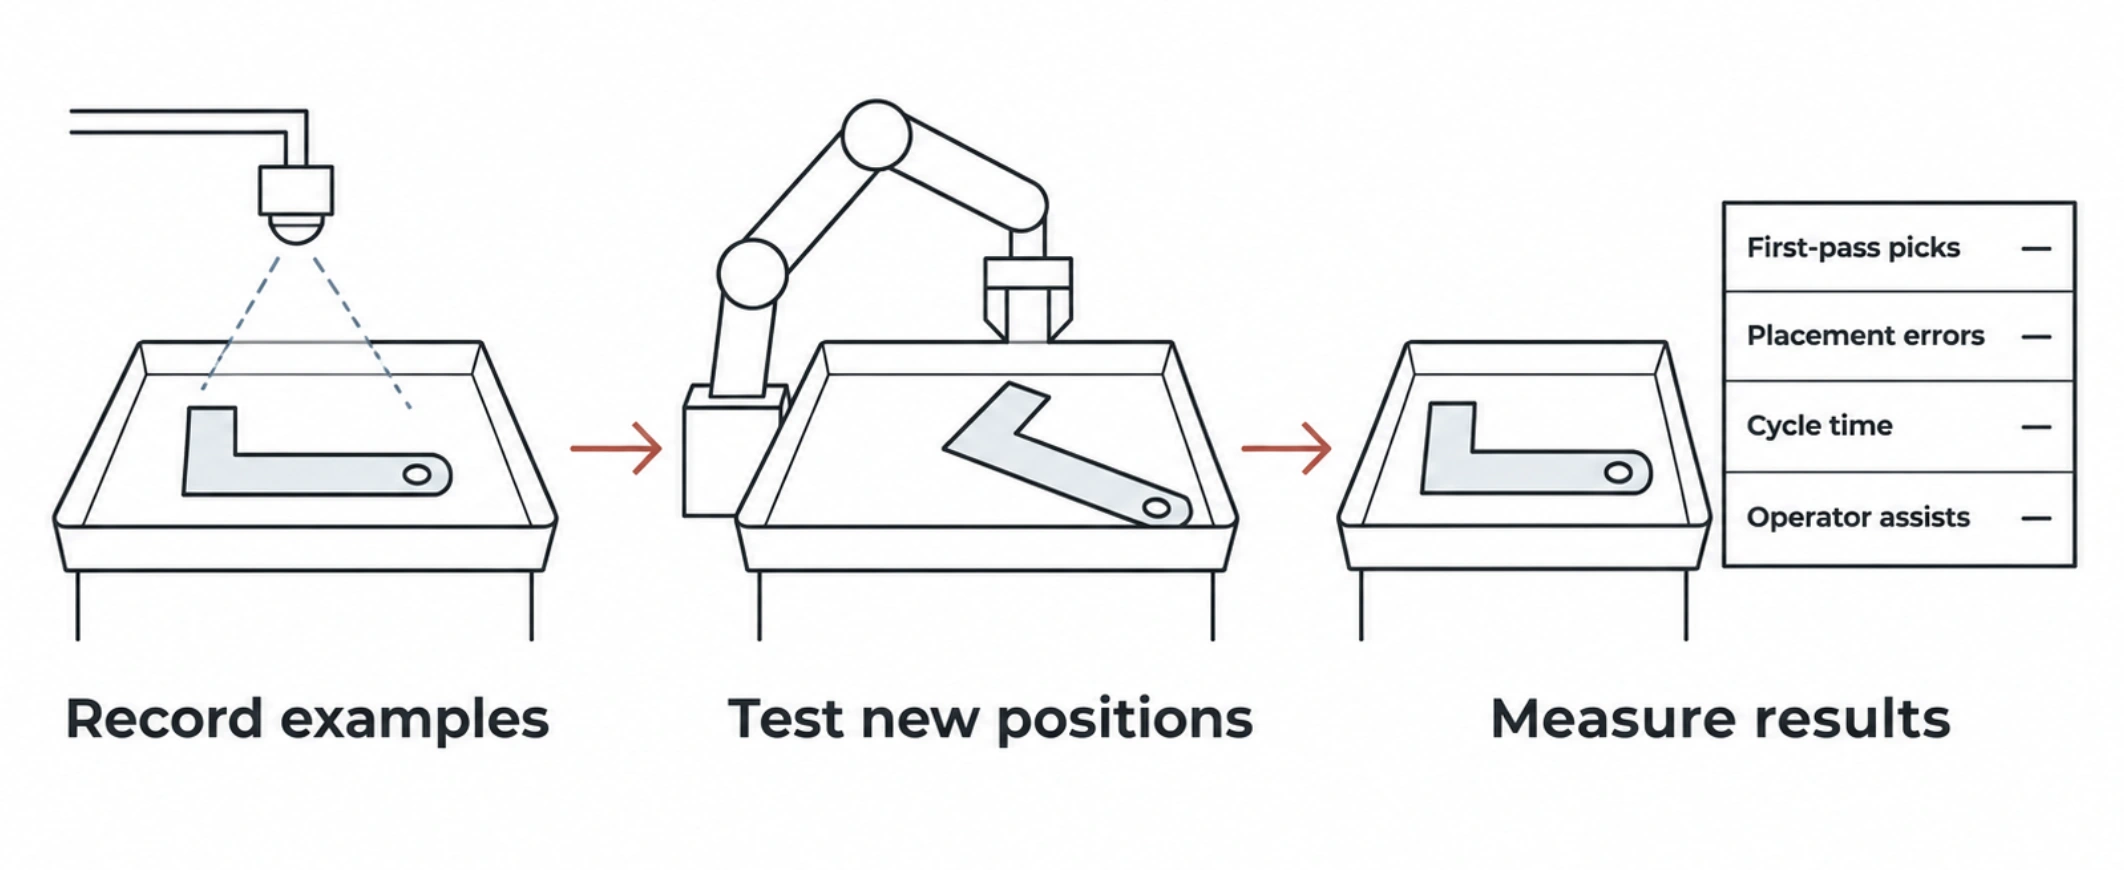
We start from reusable robot skills where they fit and adapt them with demonstrations from your line. For example, a camera-guided station can learn to pick the same part when it arrives rotated or offset in a tote.
SF Robotics co-founder Rahul Chand contributed to NVIDIA’s GR00T N1.6 foundation model for humanoid robots.
Read our prior research at NVIDIARahul Chand and Miguel Villa Floran compared how six vision-language-action models adapt as the number of demonstrations changes across four simulated task suites.
Read the preprintSONIC shows how a humanoid robot can combine whole-body motion tracking with higher-level plans to walk up to objects and manipulate them.
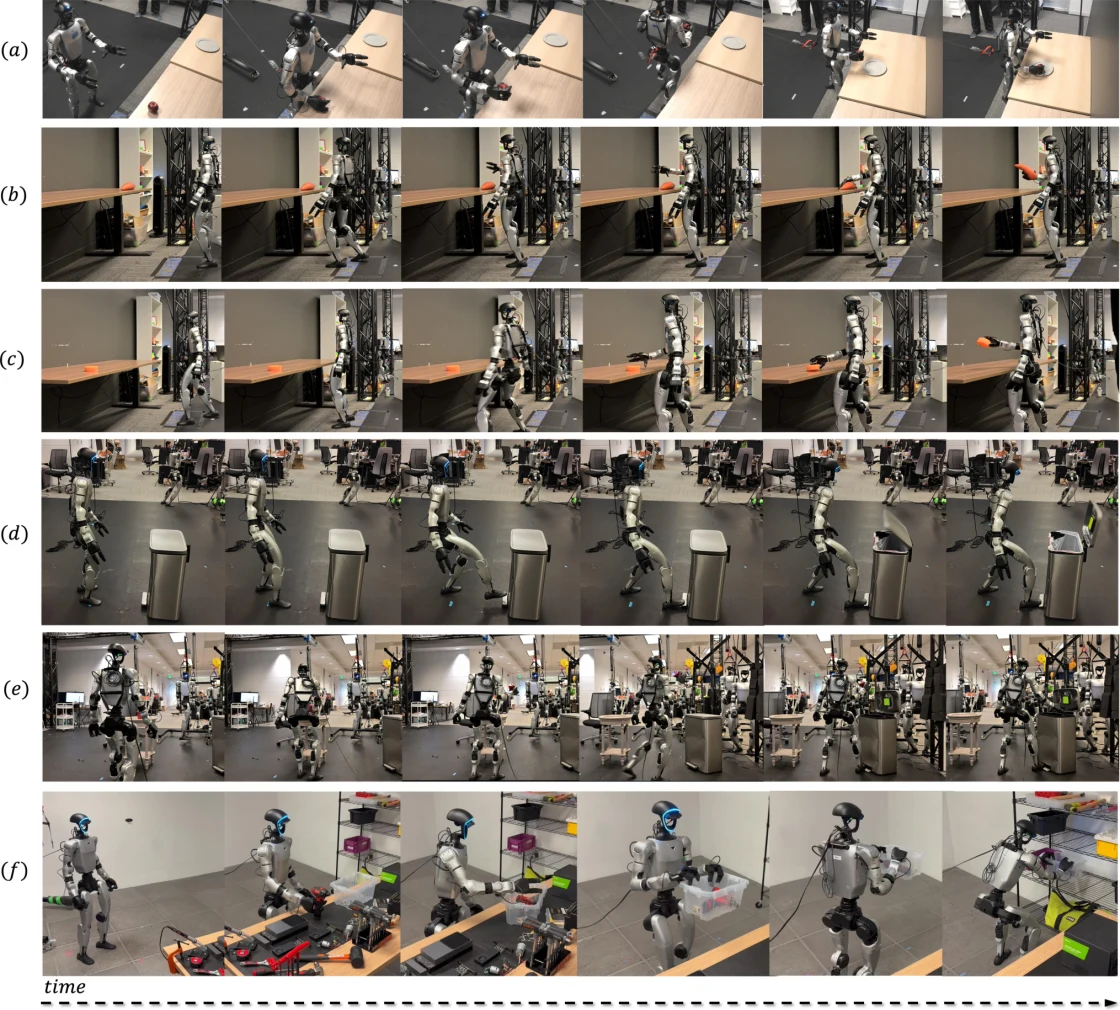
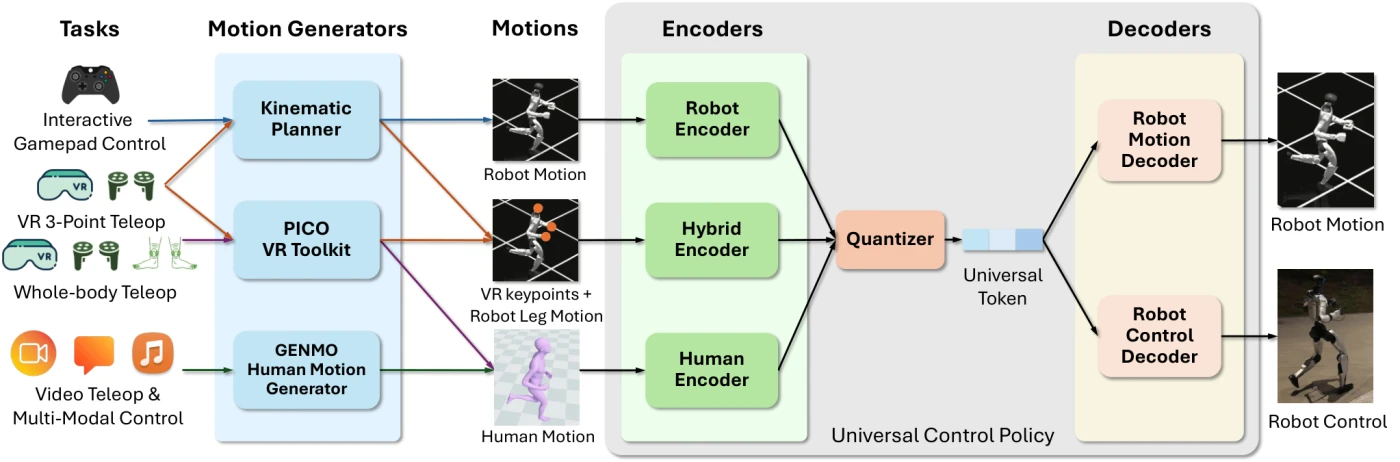
Figures 5 and 7 by Luo et al., resized for this page. NVIDIA release · Read the SONIC paper · CC BY-SA 4.0