SF Robotics
Discuss a project

Assembly support

Robotic stations for part positioning, insertion and fastening.

What we develop

We build robotic and automated stations for component positioning, insertion, fastening and inspection.
  • Vision-guided orientationLocate brackets, housings and fittings. Pick them with parallel-jaw or vacuum tooling.
  • Fixture loading and clampingSeat parts against locating pins or stops in a nest and hold them with clamps.
  • Guided insertionFit keyed components or connectors using compliant tooling where the fit calls for it.
  • ScrewdrivingFeed and drive fasteners with a guided spindle. Check seating depth or torque when the driver reports it.
  • Vision checksVerify part presence, orientation or visible fastener seating before handoff.
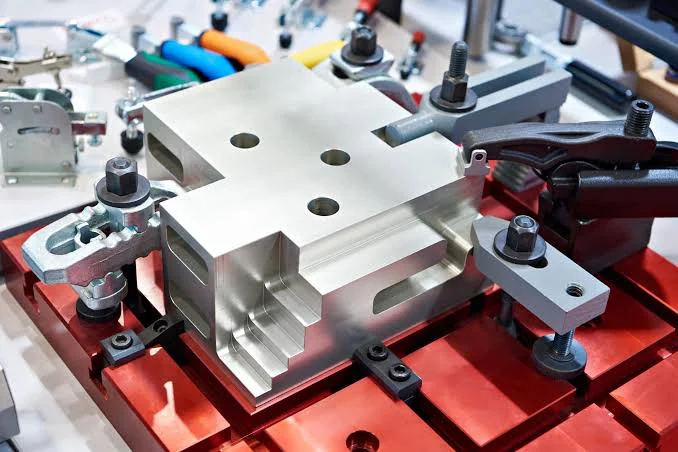
Machined metal part held in place by adjustable clamps
Part held in a locating fixture

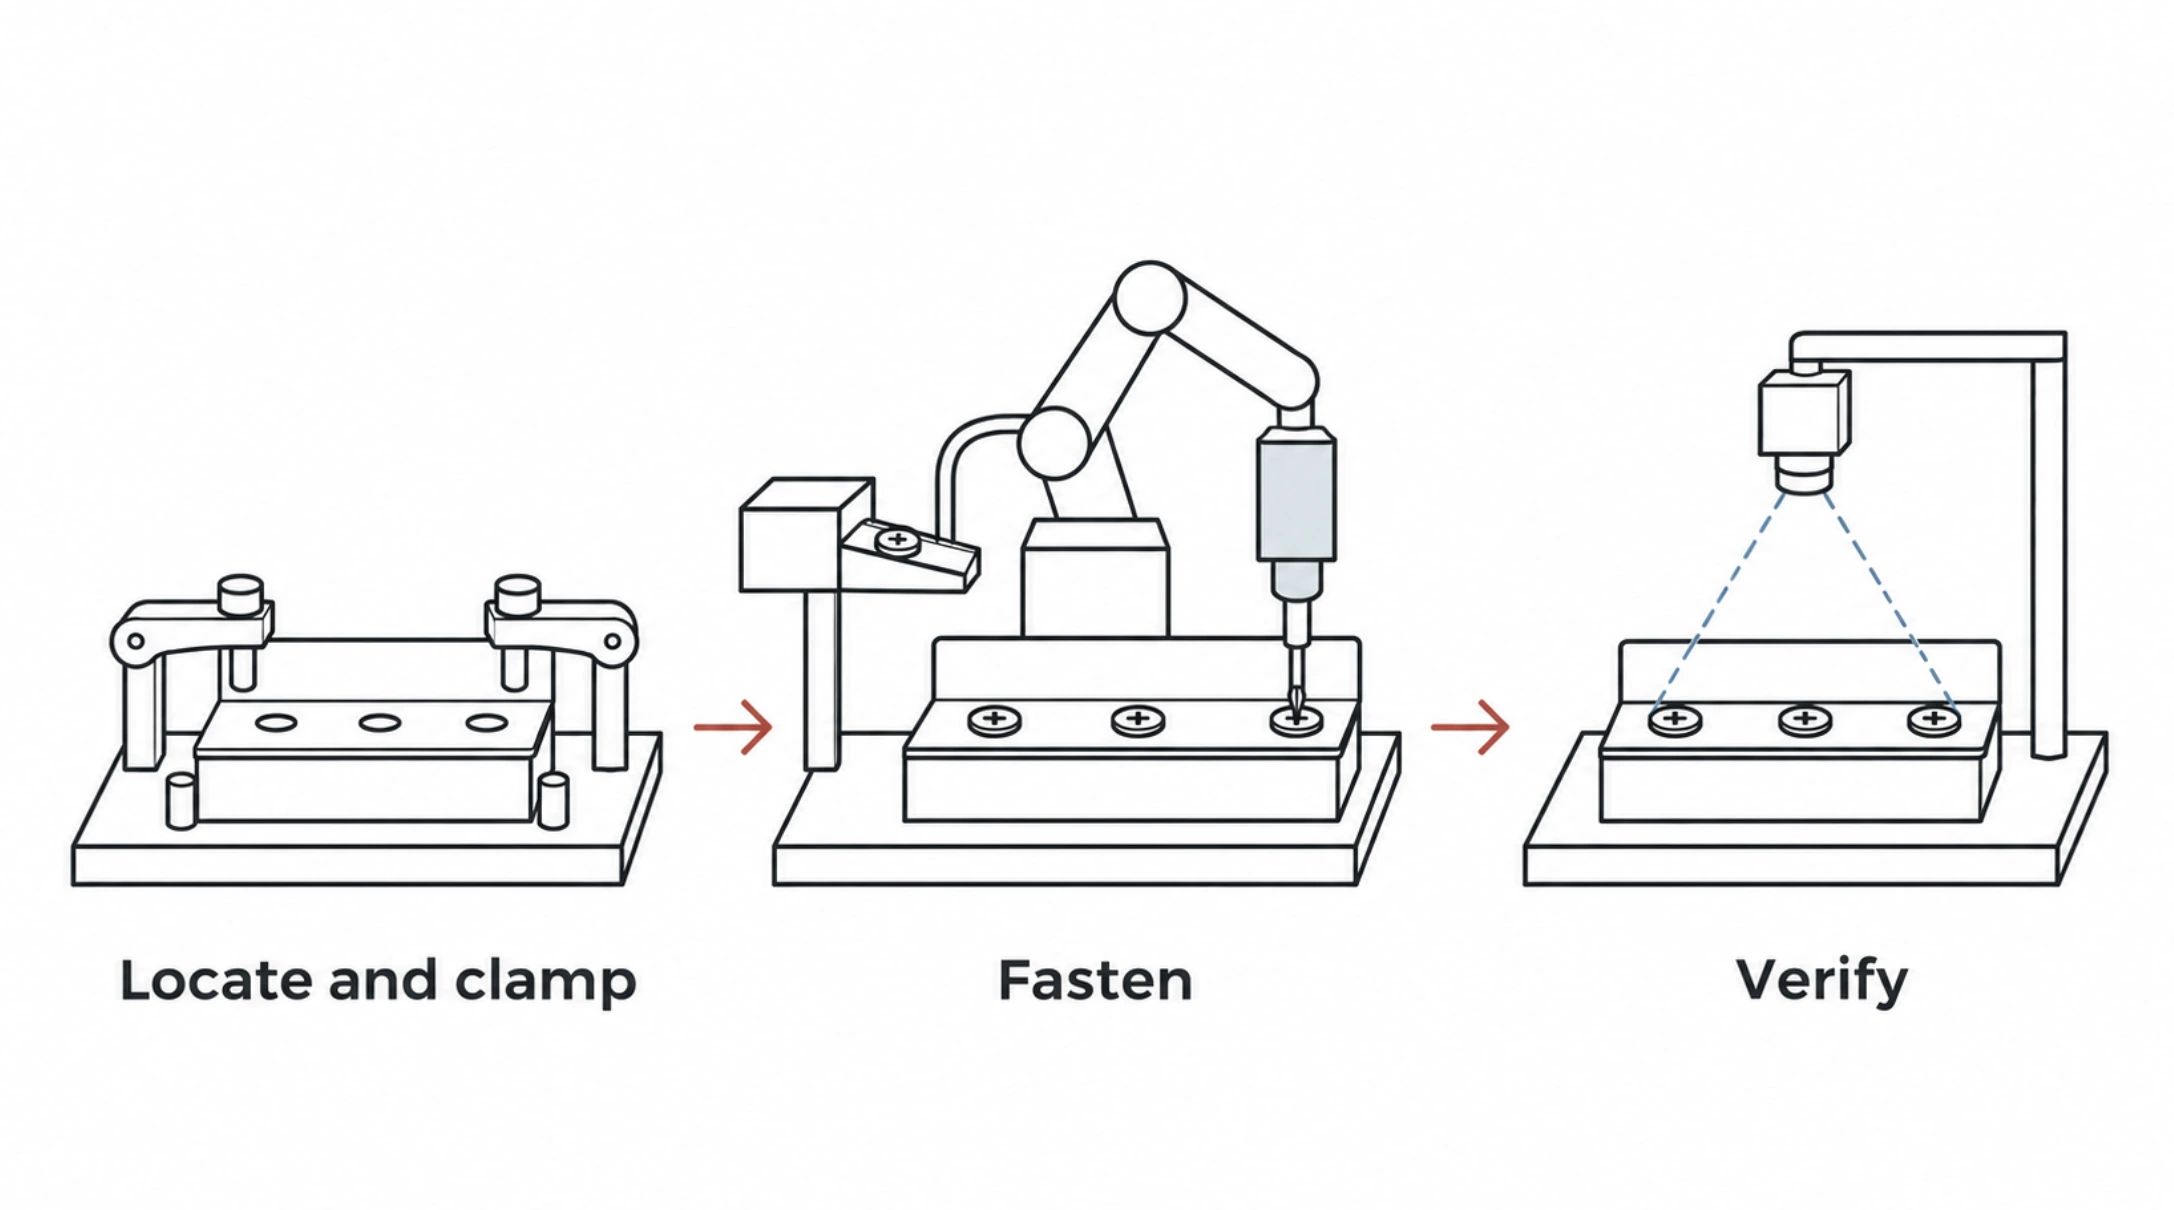
Example fixture and fastening station

  1. Orient the bracket and housing, then locate and clamp them in a fixture.
  2. Feed the fasteners and drive them with a guided spindle.
  3. Check fastener presence and seating before handing the assembly to the next station.
A fixture locates and clamps a part, a robot drives the fasteners, and a camera checks the finished assembly.

Locating surfaces and fit

Bring the part drawings and sample assemblies, including tight fits and variants. Check datum, insertion depth and access around the fixture.

Grip, clamp and tool access

Test whether the robot can reach the fasteners and keep the part supported through insertion or tightening.

Assembly acceptance

Agree which checks release a part, such as fastener presence, visible seating or torque data from the driver. Test a missing fastener and an incomplete insertion.

Discuss an automation project

Contact SF Robotics